SYSTEM INITIALIZING... 0%
CURRENT DEPTH
-0 m
SUNLIGHT ZONE

WENQIAN (VINCENT)
ZHANG

Robotics & Embodied AI Researcher

I work on reliable robot learning—world and action models, agent-guided failure recovery, and sim-to-real adaptation—grounded in real-robot systems I build and evaluate.

Computer Engineering @ UC Riverside · TASL, advised by Prof. Jiachen Li

View Selected WorkView CV
World Action ModelsFailure RecoverySim-to-RealReal-World ManipulationMultimodal Behavior

Research & Focus

How can robots stay reliable when the real world departs from what they were trained on?

My research focuses on reliable robot learning: helping robots recover when a policy fails, using world and action models to guide that recovery, and closing the gap between simulation and the real robot. I also study multimodal behavior understanding, inferring intent from what an agent does rather than from the scene around it.

At TASL (advised by Prof. Jiachen Li), I am co-first author of a paper under review on agent-guided failure recovery with world action models, where I built the visual grounding and intervention control and ran ablations across OpenWAM and Cosmos 3 Edge. I am also a co-author of LIBERO-PeRM (NeurIPS 2026), a benchmark for personalized robotic manipulation, where I helped design the preference-composition, preference–scene disentanglement, and preference-conflict conditions. On the systems side, I built the lab's Franka FR3 platform and the real-robot deployment stack for AXIS-Bench.

As a Chancellor's Research Fellow with Prof. Christian Shelton, I extend CatSignal, my first-author CVPR 2026 CV4Animals paper, into tests of scene shortcuts on 879 curated clips.

In summer 2026, at a stealth robotics startup in San Francisco, I built dual-arm teleoperation, human-intervention, and Isaac Lab data pipelines.

Selected Works

AUTONOMOUS · π0.5 · 1×

01 / 04Franka / VLA / Real-World Robotics

Franka FR3

Franka FR3 Robot Learning Cell

Built a Franka Research 3 manipulation cell from scratch — bench, real-time control, cameras, gripper, GELLO teleoperation, and in-the-wild VLA rollouts.

View project
AUTONOMOUS · π0.5 · 1×

01Franka / VLA / Real-World Robotics

Franka FR3 Robot Learning Cell

Built a Franka Research 3 manipulation cell from scratch — bench, real-time control, cameras, gripper, GELLO teleoperation, and in-the-wild VLA rollouts.

View project
TELEOP · LEADER → FR3 · 1×

02Franka / Teleoperation / Hardware

GELLO Build Guide

A detailed hardware build of a 3D-printed GELLO leader arm for FR3 teleoperation, including Dynamixel bring-up, wiring, spring installation, and calibration pitfalls.

View project
AUTONOMOUS · MTDiT + RTC · 1×

03Stealth Startup / Bimanual YAM / LeRobot

Dual-Arm Manipulation & Imitation Learning

LeRobot integrations for a bimanual YAM cell, a public 50-episode dataset, real-time chunking and human takeover for Multi-Task DiT, and a 16-environment Isaac Lab data factory.

View project
POSE + AUDIO + CONTEXT

04AI Research / Multimodal Intent Inference

CatSignal — CVPR 2026

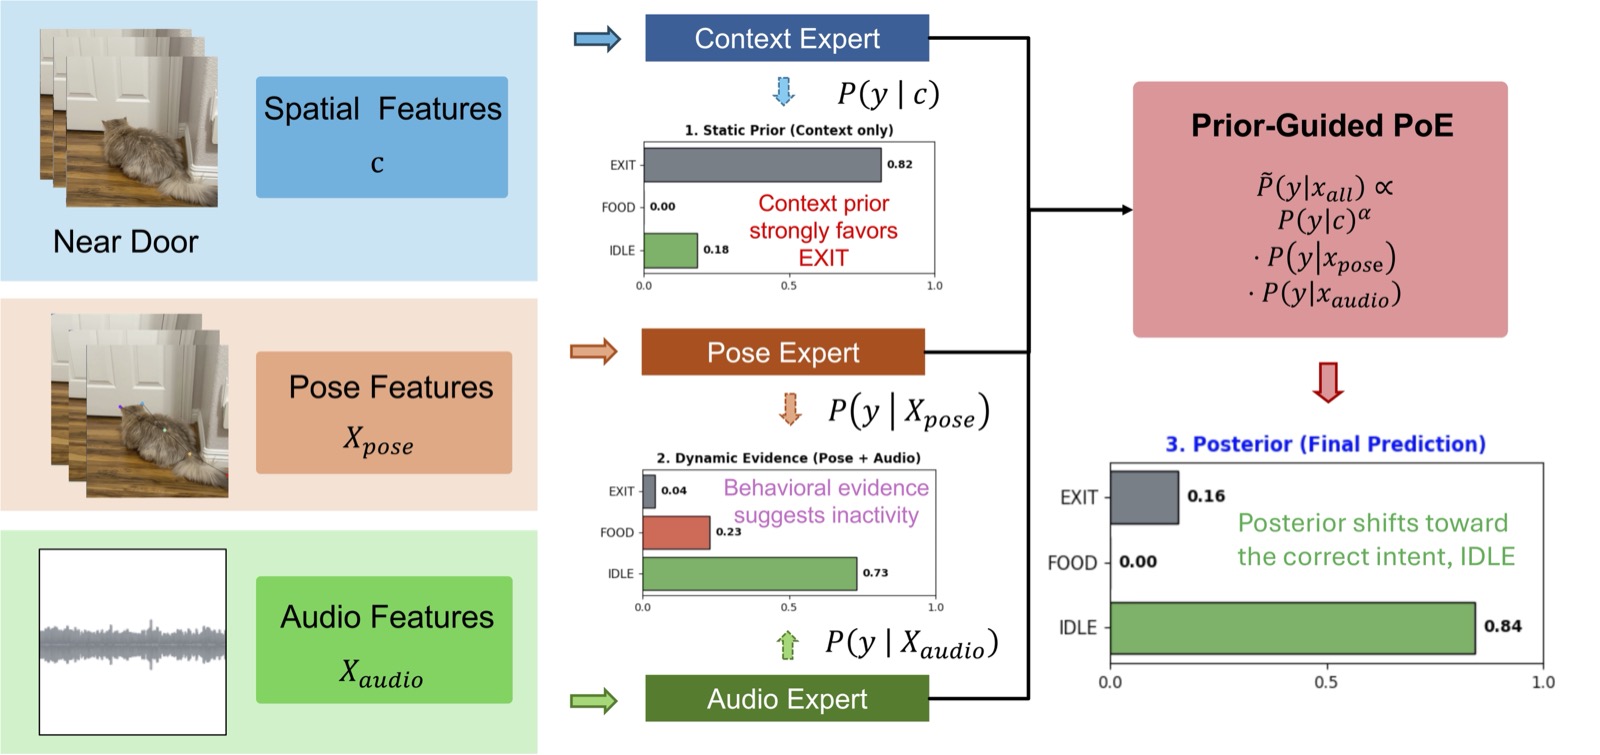
A Bayesian-inspired multimodal framework for inferring intent in non-speaking agents using spatial context, pose dynamics, and audio evidence.

View project

Publications & Recognition

CatSignal: context as prior, pose and audio as evidence

CVPR 2026 · CV4Animals Workshop

Context as Prior: Bayesian-Inspired Intent Inference for Non-Speaking Agents with a Household Cat Testbed

Wenqian Zhang, Zehao Wang

Intent inference for non-speaking agents with household cats as a real-world testbed: spatial context acts as a Bayesian prior while pose and audio supply behavioral evidence that can overturn misleading context.

Accepted · PosterFirst Author
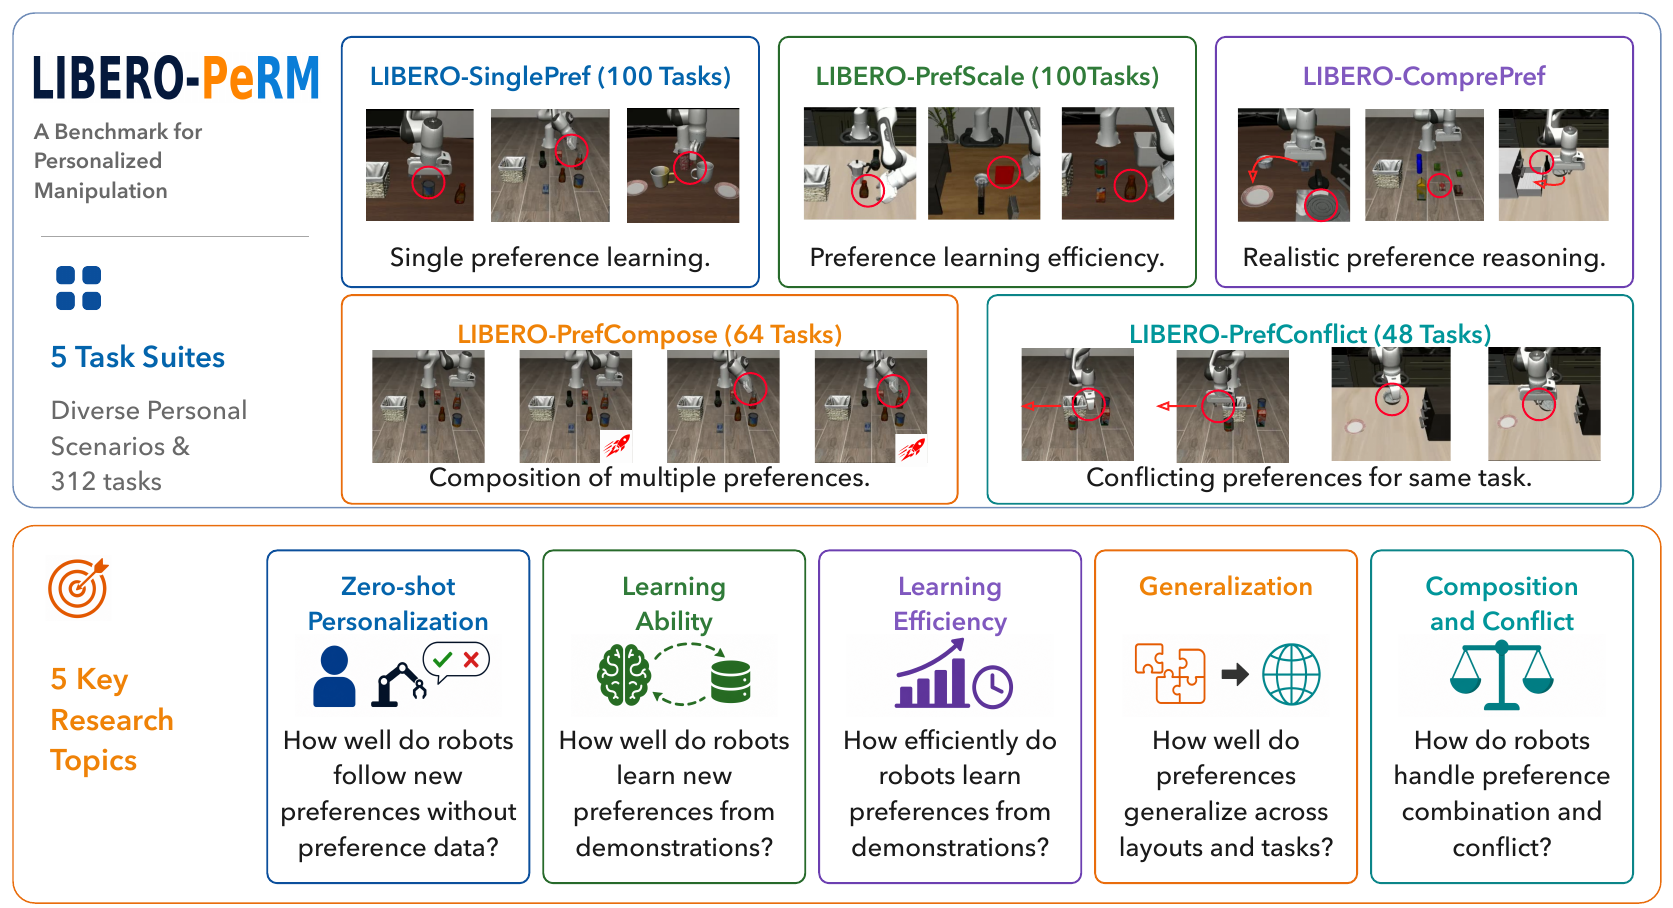
LIBERO-PeRM overview: five task suites and five research topics

NeurIPS 2026 · Evaluations & Datasets

LIBERO-PeRM: Benchmarking Personalized Robotic Manipulation

Zhixu Li*, Keqian Tang*, Litian Gong*, Jingyu Yao, Wenqian Zhang, Tianze Xu, Zehao Wang, Yuping Wang, Junge Zhang, Jiachen Li

A LIBERO-based benchmark asking whether a policy can do the task the way you want it done: 312 tasks in five suites, paired demonstrations with and without preferences, and automatic preference-satisfaction metrics. I helped design and implement the preference-composition, preference–scene disentanglement, and preference-conflict conditions and their task variants.

Accepted · PosterCo-Author

Preprint

What Matters in Quality-Aware VLA Pretraining: A Benchmark and Empirical Study

Mingxuan Yan, Litian Gong, Dihong Huang, Zhixu Li, Tianyu Zhang, Wenqian Zhang, … Jiachen Li (21 authors)

Under Review · ICRA 2027arXiv

May 2026 · UC Riverside

Chancellor's Research Fellowship

Undergraduate research fellowship supporting the extension of CatSignal into unsupervised multimodal behavior discovery.

Apr 2026 · UC Riverside

Undergraduate Education Mini-Grant

Travel support to present the accepted paper at the CVPR 2026 CV4Animals Workshop.

Let's Connect

Open to research collaborations and strong opportunities in robotics and embodied AI.

EmailLinkedInGitHubCV

Beyond research: games, photography, travel, quiet time with literature—and Yuanbao, my British Shorthair, who unexpectedly inspired a paper.

© 2026 Wenqian Zhang. All rights reserved. Built with Next.js & R3F.